Around the World: Unified Learned Locomotion on a 270 g Continuous-Rotation Quadruped
Videos
Continuous Walking
Multiple Throws
Different Floors
Abstract
Closed-loop learned locomotion has matured on commercial quadrupeds but remains uncommon at the sub-kilogram scale. We present a single learned policy that handles throw recovery, multi-posture walking, and hardware variation on the MiNI-Q, a 270 g quadruped whose belt-driven legs rotate continuously through 360°. The same trained network switches between posture targets on the joint torus T8, walks upright and inverted under a gravity-conditioned reference, and recovers from arbitrary spawn orientations, all without state machines or phase switching. We identify the Dynamixel XL330 actuators across their operating regimes, cross-validate the trained policy in MuJoCo, Isaac Gym, and Isaac Lab, and deploy a compact sub-100k-parameter network onboard at 50 Hz on a dual-microcontroller stack. We further train under foot-shape domain randomization and verify on hardware that the same policy walks across multiple printed lower-link variants swapped at test time. The result is a single learned controller for throw recovery, multi-posture walking, and hardware variation, all on the same miniature robot.
Simulation
IsaacGym
IsaacLab
MuJoCo
Locomotion With Different Gaits
ANYmal
Crouch
Q8bot
Inverted ANYmal
Inverted Crouch
Inverted Q8bot
Throws
Upright Pitch
Upright Roll
Inverted Pitch
Inverted Roll
Disturbance
Flip
Nudge
Breakdance
Foot Iterations
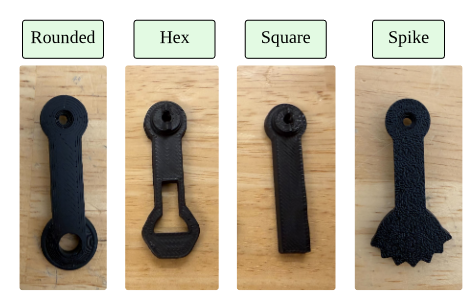
Photo of all the Feet
Changing Foot (less than 1 minute!)
Walking with Different Feet
Additional Results
Different MiNIQ
Attitude Control (Roll Pitch)
BibTeX
Coming soon once accepted! 😝